Lie Theory
Table of Contents
1. Lie Group
1.1. SO(3) and SU(2)
\(\mathrm{SO}(3)\) has two elements in its fundamental group \(\pi\).
- Class I: which wraps around, with odd number of crossing
- Class II: which does not wrap, with even number of crossing
\(\mathrm{SU}(2)\) is, however, simply connected, and it double covers \(\mathrm{SO}(3)\). Spinor is the thing that is transformed by the \(\mathrm{SU}(2)\).
1.1.1. Topology
\(\mathrm{SO}(3)\) has the topology of three dimensional real projective space \(\mathbb{RP}^3\) and \(\mathrm{SU}(2)\) has the topology of the 3-sphere \(\mathbb{S}^3\).
1.1.2. Flagpole Representation
Even though a spinor cannot be represented on a sphere, the overall phase and the spin state can also be represented by a flagpole.
- The axis of the flagpole represents the direction of the spin state, as in the Bloch sphere.
- The angle of the flag on the pole represents the overall phase, which rotates as the time forwards, counterclockwise if matter, clockwise if antimatter. The overall phase double covers the flag angle.
2. Lie Algebra
Lie algebra element is represented by a tangent vector field of the flow in a manifold the continuously parametrized Lie group element creates.2
Lie algebra is the tangent space of a Lie group at the identity.3, 4
Adding two Lie algebra elements results in another Lie algebra element. Given two curves \(A(t)\), \(B(t)\) on Lie group \(G\) with \(A(0)=B(0)=1\), \(A'(0)=a\in T_eG\) and \(B'(0)=a\in T_eG\), we have \((A(t)B(t))'(0)=a+b\in T_eG\).
2.1. Lie Bracket
Lie bracket let us calculate the group multiplication of Lie group within Lie algebra, and the properties of Lie bracket match the properties of group multiplication.
Lie bracket is defined to satisfy the Jacobi identity: \[ [X, [Y,Z]] + [Y, [Z,X]] + [Z, [X, Y]] = 0. \]
2.1.1. Derivation
We want to define some kind of multiplication on the tangent space \(T_eG\) of Lie group \(G\) at the identity element \(e\).
For \(A, B \in T_{e}G\) and its Lie group elements \(a = e^{tA},b = e^{sB} \in G\), \( AB = \not\in T_eG,\) in general. Let me give a general reasoning for that: We know that \( aB\in T_{a}G \) using the straightforward differential of linear operation. Now if we try to take the derivative of \(B\) with respect to \(t\), a component outside of tanget space can arise as the tangent spaces can be in different orientation in higher dimensional space..
Meanwhile the adjoint action \(\mathrm{Ad}_b(A)\) always produces a valid Lie algebra element: \[ \mathrm{Ad}_b(A) := bAb^{-1}\in T_eG \] because
\begin{align*} b &e^{t A} b^{-1} \Big|_{t=0} = e, \\ b &e^{t A}b^{-1} \in G, \\ \dv{t} &b e^{t A}b^{-1} \Big|_{t=0} = bAb^{-1} \in T_e G, \end{align*}From the fact that Lie algebra is closed under addition and scalar multiplication, we can see that \(BA - AB\) is also in Lie algebra:
\begin{align*} \forall s, &e^{sB} A e^{-sB} \in T_eG, \\ \dv{s} &e^{sB} A e^{-sB} \Big|_{t=0} = BA - AB \in T_eG \end{align*}This quantity represent the rate of change of of the vector field \(A\) in the representation in the direction given by \(B\) at each point.
We define it to be the Lie bracket. \[ [B,A] := BA - AB. \]
2.1.2. Properties
Distribution Rule \[ [X,[Y,Z]] = [[X, Y], Z] + [Y, [X, Z]] \] which is the generalization of the adjoint operation.5 \[ [[X,Y],Z] = [X, [Y, Z]] - [Y, [X, Z]] \]
3. Exponential Map
An element of Lie algebra \(\mathfrak{g}\) can map to the element of Lie group \(G\) by the exponential map \(\exp\colon \mathfrak{g} \to G\).
When an element of Lie algebra is represented by a matrix the exponential map correspond to the exponential function on matrices.
3.1. Logarithmic Map
Lie group can be reduced to Lie algebra through logarithmic map, in which it is easier to do calculations.
4. Cartan Subalgebra
- CSA
Nilpotent subalgebra \(\mathfrak{h}\subset \mathfrak{g}\) that is self-normalizing: \[ \forall X, Y \in \mathfrak{h}, [X,Y] \in \mathfrak{h}. \]
They include the diagonal matrices \(H\), since they vanish under Lie bracket.
5. Representations
5.1. sl(2, R)
\(\mathfrak{sl}(2)\) is three dimensional with the basis vectors satisfying:
\[ [H, E] = 2E,\quad [H, F] = -2F,\quad [E, F] = H. \]
Two real dimensional representation is \[ \textcolor{RoyalBlue}{H} \equiv \begin{pmatrix} 1 & 0 \\ 0 & -1\end{pmatrix} \quad \textcolor{OrangeRed}{E} \equiv \begin{pmatrix} 0 & 1 \\ 0 & 0\end{pmatrix} \quad \textcolor{ForestGreen}{F} \equiv \begin{pmatrix} 0 & 0 \\ 1 & 0\end{pmatrix}. \]
The representation of sl(2) on five dimensional vector space acting on the vector space with five basis vectors:
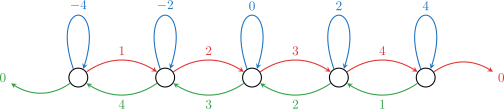
In matrix form, \[ H= \begin{pmatrix} -4&0&0&0&0\\ 0&-2&0&0&0\\ 0&0&0&0&0\\ 0&0&0&2&0\\ 0&0&0&0&4 \end{pmatrix},\quad E= \begin{pmatrix} 0&0&0&0&0\\ 1&0&0&0&0\\ 0&2&0&0&0\\ 0&0&3&0&0\\ 0&0&0&4&0 \end{pmatrix},\quad F= \begin{pmatrix} 0&4&0&0&0\\ 0&0&3&0&0\\ 0&0&0&2&0\\ 0&0&0&0&1\\ 0&0&0&0&0 \end{pmatrix}. \]
5.2. sl(2, C)
Since sl(2,C) is the complexification of sl(2,R), the representations of sl(2,R) can be used for sl(2,C) with complex coefficients.
\(\mathfrak{sl}(2,\mathbb{C})\) can also be represented by the direct sum of two representations of su(2) related by complex conjugation, due to the peculiar relation:
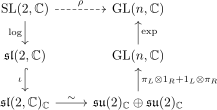 where the subscript \(\mathbb{C}\) means the complexification, and the inclusion
\(\iota\) is such that the representations of left and right chiral spinor are
related by complex conjugation.
In physics, each representation is labeled by the spins of the two su(2) representations. e.g. (1/2, 1/2).
5.3. sl(3, R)
\(\mathfrak{sl}(3, \mathbb{R})\) is a eight dimension with basis vectors \[ H_1, H_2, \textcolor{OrangeRed}{E_1}, \textcolor{ForestGreen}{E_2}, F_1, F_2, [F_1, F_2], [E_1, E_2] \] and whose adjoint representation looks like:
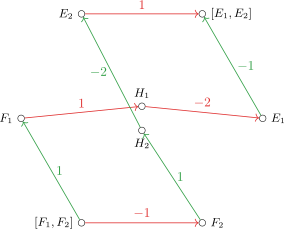 where arrows mean adjoint action defined to be
\[
\mathrm{ad}_X\colon \mathfrak{g} \to \mathfrak{g} \colon Y \mapsto [X,Y].
\]
5.4. su(2)
For any complex dimension \(d = 2j + 1\), the three su(2) generators in the standard basis are:
\begin{aligned} T_1 &=-\frac{i}{2} \begin{bmatrix} 0&c_1&&&\\ c_1&0&c_2&&\\ &c_2&0&\ddots&\\ &&\ddots&\ddots&c_{d-1}\\ &&&c_{d-1}&0 \end{bmatrix}, \\ T_2 &=\frac12 \begin{bmatrix} 0&-c_1&&&\\ c_1&0&-c_2&&\\ &c_2&0&\ddots&\\ &&\ddots&\ddots&-c_{d-1}\\ &&&c_{d-1}&0 \end{bmatrix}, \\ T_3 &=-\frac{i}{2}\mqty[\dmat{d-1,d-3,\ldots,1-d}] \end{aligned}where \(c_k=\sqrt{k(d-k)}\).
They satisfy: \[ [T_a,T_b]=\epsilon_{abc}T_c,\qquad T_a^\dagger=-T_a. \]
The Hermitian angular-momentum matrices are directly related to this: \(J_a=iT_a\).
For example, d=1 \[ T_1=T_2=T_3=0. \]
d=2 (or spin-1/2): \[ T_1=-\frac{i}{2} \begin{pmatrix}0&1\\1&0\end{pmatrix},\qquad T_2=\frac12 \begin{pmatrix}0&-1\\1&0\end{pmatrix},\qquad T_3=-\frac{i}{2} \begin{pmatrix}1&0\\0&-1\end{pmatrix}, \] or equivalently using Pauli matrices, \[ T_a = - \frac{i}{2}\sigma_a. \]
d=3 (or spin-1): \[ T_1=-\frac{i}{\sqrt2} \begin{pmatrix}0&1&0\\1&0&1\\0&1&0\end{pmatrix},\qquad T_2=\frac1{\sqrt2} \begin{pmatrix}0&-1&0\\1&0&-1\\0&1&0\end{pmatrix},\qquad T_3=-i \begin{pmatrix}1&0&0\\0&0&0\\0&0&-1\end{pmatrix}. \]
5.5. SU(2)
SU(2) has unique irreducible representation for each complex dimension derived from the representations of su(2).
5.6. SU(3)
SU(3) has two distinct irreducible representation on three complex dimension related by complex conjugation: \(\mathbf{3}\) and \(\bar{\mathbf{3}}\).
| Dimension | Irrep | Label |
|---|---|---|
| 1 | trivial (singlet) \(\mathbf{1}\) | (0,0) |
| 2 | none | — |
| 3 | \(\mathbf{3}\) | (1,0) |
| \(\bar{\mathbf{3}}\) | (0,1) | |
| 4 | none | — |
| 5 | none | — |
| 6 | \(\mathbf{6}\) | (2,0) |
| \(\bar{\mathbf{6}}\) | (0,2) | |
| 8 | \(\mathbf{8}\) | (1,1) |
| 10 | \(\mathbf{10}\) | (3,0) |
| \(\bar{\mathbf{10}}\) | (0,3) | |
| 15 | \(\mathbf{15}\) | (2,1) |
| \(\bar{\mathbf{15}}\) | (1,2) | |
| \(\mathbf{15}'\) | (4,0) | |
| \(\bar{\mathbf{15}}'\) | (0,4) | |
| 27 | \(\mathbf{27}\) | (2,2) |
6. Root System
Some of the Lie algebra can be represented in a finite way, which in turn form a simple set of vectors that represents the structure of the Lie algebra.
6.1. Root
A Lie algebra \(\mathfrak{g}\) can be decomposed into \[ \mathfrak{g} = \mathfrak{h} \oplus \bigoplus_{\alpha \in \Phi} \mathfrak{g}_{\alpha} \] where \(\mathfrak{h}\subset \mathfrak{g}\) is Cartan subalgebra, and \(\mathfrak{g}_{\alpha}\) is defined to be \[ \mathfrak{g}_\alpha := \{X\in \mathfrak{g} \colon \forall H \in \mathfrak{h}, [H,X] = \alpha(H)X\}. \] with nonzero linear functionals \(\alpha\colon \mathfrak{h} \to \mathbb{C}\) known as the roots.
For semisimple Lie algebra the vectors corresponds to the adjoint representations of Lie algebra elements, since \([\mathfrak{g}_{\alpha}, \mathfrak{g}_{\beta}] = \mathfrak{g}_{\alpha + \beta}\).
6.2. Positive Roots
- \(\Delta_+\)
Roots that are on the upper half, including the ones on the positive half of the axes.
6.3. Simple Roots
The one that corresponds to the actual basis elements within a Lie algebra.
6.4. Dynkin Diagram
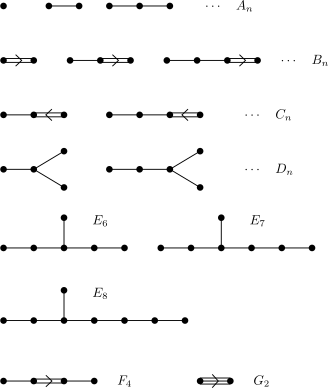
Dynkin diagram corresponds to a root system
Finite Dynkin Diagrams
6.4.1. Reconstruction of Root System
| i j | dᵢ | aᵢⱼ | 〈αᵢ, αⱼ〉= dᵢaᵢⱼ |
| i = j | 2 | 2dᵢ | |
| • • | 0 | 0 | |
| •—• | dᵢ = dⱼ | -1 | -dᵢ |
| •=>=• | 2 | -1 | -2 |
| •≡>≡• | 3 | -1 | -3 |
| •=<=• | 1 | -2 | -2 |
| •≡<≡• | 1 | -3 | -3 |
Note \(\|\alpha_i\| = \sqrt{2d_i}\)
\(a_{ij}\) is the entries of the Cartan matrix and can equivalently be defined as: \[ a_{ji} = 2\frac{\langle \alpha_i, \alpha_j\rangle}{\langle \alpha_j, \alpha_j\rangle}. \]
6.4.2. Exceptional G2
- \(\mathfrak{g}_2\)
- The Cross Product and the Exceptional G2 - YouTube
- The result of the 7-Dimensional cross product generally does not follow the transformation rule.
- But there's subgroup of the \(\mathfrak{so}(7)\), which contains 14 families of two-plane rotation that preserves the relationship. This is the G2.
- The existence is based on the multiplicative property of the octonion. G2 is the automorphism group of octonions.
7. Classification
7.1. Complex Simple Lie Algebra
There are only following finite dimensional complex simple Lie algebras:
- Four infinite families \(A_n,\ B_n,\ C_n,\ D_n\)
- Five exceptional Lie algebras \(E_6, E_7, E_8, F_4, G_2\).
\(n\) is the rank which is the number of nodes in the Dynkin diagram, and also the number of simple roots.
- \(A_n\) is \(\mathfrak{sl}(n+1)\)
- \(B_n\) is \(\mathfrak{so}(2n+1)\)
- \(C_n\) is \(\mathfrak{sp}(2n)\) symplectic Lie algebra
- \(D_n\) is \(\mathfrak{so}(2n)\)
For low dimension, several importanct isomorphism occurs:
\begin{align*} \mathfrak{su}(2) &\cong \mathfrak{so}(3) \\ \mathfrak{su}(2) \oplus \mathfrak{su}(2) &\cong \mathfrak{so}(4) \\ \mathfrak{su}(4) &\cong \mathfrak{so}(6). \end{align*}One Dynkin type can have multiple real forms. For example \(A_2 = \mathfrak{sl}(3,\mathbb{C})\) has three: \[ \mathfrak{su}(3), \mathfrak{su}(2,1), \mathfrak{sl}(3,\mathbb{R}). \] In particular, complexification of \(\mathfrak{su}(n)\) always has following isomorphism \[ \mathfrak{su}(n)_{\mathbb{C}} \cong \mathfrak{sl}(n, \mathbb{C}). \]
8. Complexification
8.1. Lie Algebra
The canonical complexification of Lie algebra \(\mathfrak{g}\) is: \[ \mathfrak{g}_{\mathbb{C}} := \mathfrak{g}\otimes_{\mathbb{R}} \mathbb{C} = \mathfrak{g} \oplus i\mathfrak{g}. \]
8.2. Lie Group
Universal complexification of a Lie group \(G\) is a complex Lie group \(G_{\mathbb{C}}\), such that for arbitrary continuous homomorphism \(f\) into a complex Lie group \(H\) there exists \(F\) such that the following diagram commutes

9. Baker-Campbell-Hausdorff Formula
- BCH Formula
Formula for \(Z\) that solves \(e^Xe^Y = e^Z\) with \(X, Y\) in the Lie algebra. It is not necessarily convergent.
Baker, Campbell, Hausdorff only stated the qualitative form of the formula, that it can be written in terms of possibly infinitely nested commutators yielding another element in the Lie algebra if it is convergent.
9.1. Dynkin's Formula
First explicit formula \[ \log(\exp X\exp Y) = \sum_{n=1}^\infty\frac{(-1)^{n-1}}{n}\sum_{\begin{smallmatrix}r_1+s_1 >0\\[-.5em] \vdots\\[.3em] r_n+s_n >0\end{smallmatrix}} \frac{[X^{r_1}Y^{s_1}X^{r_2}Y^{s_2}\cdots X^{r_n}Y^{s_n}]}{\left(\sum_{j=1}^n(r_j+s_j)\right)\cdot \prod_{i=1}^nr_i!s_i!} \] where the bracket is the notation for the Lie bracket nested on the right iterated by the exponent, and \(r_i, s_i\) are assumed to be nonnegative, with the understanding that \([X] := X\).
The first few terms are well-known to be: \[ Z(X,Y) = X+Y + \frac{1}{2}[X,Y] + \frac{1}{12}([X,[X,Y]] + [Y,[Y,X]]) -\frac{1}{24}[Y,[X,[X,Y]]] -\cdots \]
10. Reference
Footnotes:
Mathemaniac. https://youtu.be/IlqVo3sJFLE. Introduction
Mathemaniac. Lie Algebra. https://youtu.be/gj4kvpy1eCE?si=38MLHlZbAscbyMfJ
Michael Penn. https://youtu.be/2_KVbtyufq8?si=liu02OhUrZ5JYeg-
Eigenchris. https://youtu.be/IPzwqAVfce4?si=3teaHPXQgJsNIwaq
Mathemaniac. Lie Algebra. https://youtu.be/gj4kvpy1eCE?si=38MLHlZbAscbyMfJ